 Giuseppe Oriolo
Full
Professor
Dipartimento di Ingegneria Informatica,
Automatica e Gestionale (DIAG)
Sapienza Università di Roma
via Ariosto 25, 00185 Roma, Italy
tel +39
06 7727 4051
e-mail
oriolo [at] diag [dot] uniroma1 [dot] it
Google Scholar: my
citations; ResearcherID: F-3846-2011;
Scopus Author ID: 7003629456;
ORCID: 0000-0001-6153-9278
News
Bio sketch
Research interests
Recent publications
Teaching
News
- May 2026: The paper "Sensitivity-Aware Model Predictive
Control for Robots with Parametric Uncertainty", by T.
Belvedere, M. Cognetti, G. Oriolo, P. Robuffo Giordano,
published in the IEEE Transactions on Robotics in 2025,
has won the 2025
Best Paper Award of the IEEE RAS Technical Committee on
Optimization for Robotics.
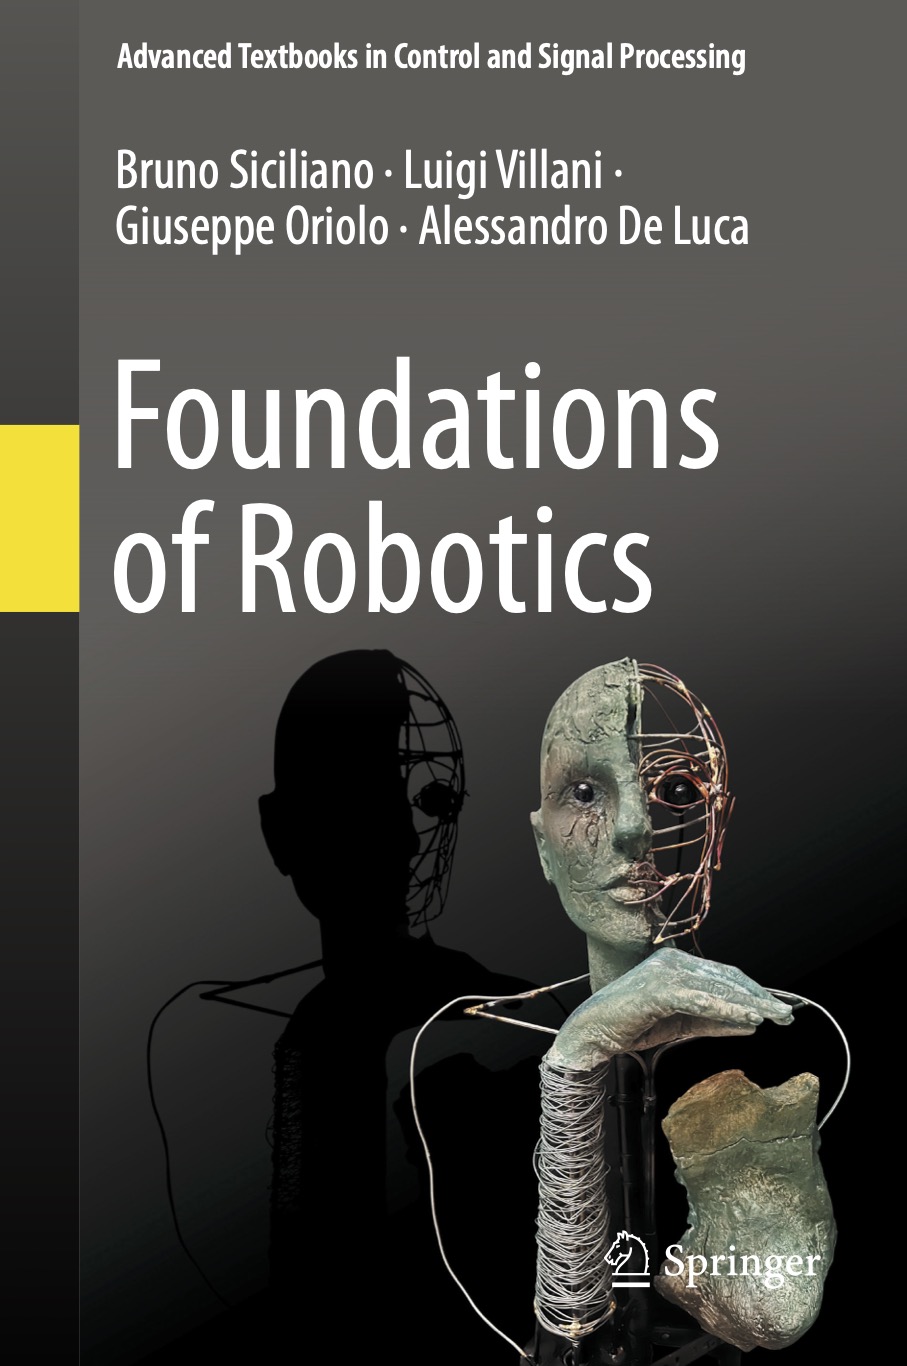
Co-authored with my
colleagues Bruno Siciliano, Luigi Villani and Alessandro De
Luca, the book is published by Springer in their "Advanced
Textbooks in Control and Signal Processing" series.
- Oct 2024: The paper "A vision-based control scheme for safe
navigation in a crowd", by P. Carboni, G. Nardini, E. Santini,
G. Gravina, M. Cipriano, F. D'Orazio, T. Belvedere, G. Oriolo,
has won the Best Paper Award at the 17th
International Workshop on Human-Friendly Robotics (HFR 2024).
- May 2020: The paper "Humanoid robots in aircraft
manufacturing: The Airbus use cases", by A. Kheddar, G. Oriolo,
L. Lanari et al, published in the IEEE Robotics &
Automation Magazine in 2019, has won the IEEE Robotics and Automation Magazine
Best Paper Award for 2020.
Bio
sketch
I received the
Ph.D. in Control Engineering in 1992 from Sapienza University of
Rome. In 1994 I joined the Department of Computer,
Control and Management Engineering (DIAG) of the same
university, where I am currently a Full Professor of Automatic
Control and Robotics. I am also the director of the DIAG Robotics Lab. I have held
teaching positions at various italian universities, including
the universities of Siena, of Cassino and of Roma Tre, and I
have been Visiting Scholar at the University of California at
Santa Barbara. I am a Fellow
of the IEEE.
I have been Associate Editor (2001-2005) and Senior Editor
(2009-2014) of the IEEE
Transactions on Robotics. I serve on the Program Committee
of several international conferences, including the European
Control Conference, the IEEE International Conference on
Robotics and Automation (ICRA), the IEEE/RSJ International
Conference on Intelligent Robots and Systems (IROS), the
IEEE-RAS International Conference on Humanoid Robots, Robotics:
Science and Systems (RSS), and many others. I
have also been Organization Chair for the 2007 IEEE
International Conference on Robotics and Automation which took
place in Rome. From 2007 to 2011 I have been on
the Conference Editorial Board of the IEEE Robotics and
Automation Society. In 2008 and 2009 I have served as Area Chair
for the RSS conference series. From 2014 to 2016 I have been
Editor of the Conference Paper Review Board of the IROS
Conference series.
Research interests
My research
interests are in control and robotics, and in particular:
humanoid robots; mobile robots; UAVs; visual
motion control; multi-robot systems; sensor-based map building,
localization and navigation; remote control and laboratories;
motion planning; learning control; kinematically redundant
robots; assistive robotics. In these areas I have published
3 books and over 230 papers in international journals and
conferences. A description of some recent research is here.
Recent publications
(a complete list of publications is here)
- A. S. Habib, N. Scianca, L.
Lanari, G. Oriolo, "Feasibility-based convexification of
MPC footstep constraints for humanoid gait generation,"
IEEE Robotics and Automation Letters, vol. 11, no. 10,
pp. 11450-11457, 2026 (pdf)
(link).
DOI:10.1109/LRA.2026.3723320
- G. Gravina, F.
D'Orazio, M. Cipriano, T. Belvedere, G. Oriolo, "Crowd
navigation in a multi-room environment: A model predictive
control framework for mobile robots," Frontiers in
Robotics and AI, vol. 13, pp. 1-19, 2026 (pdf) (link).
DOI:10.3389/frobt.2026.1812386
- F. D’Orazio, S.
Samavi, X. Du, S. Zhou, G. Oriolo, Angela P. Schoellig, "SM2ITH:
Safe mobile manipulation with interactive human prediction via
task-hierarchical bilevel Model Predictive Control," 2026
IEEE International Conference on Robotics and Automation,
Vienna, Austria, pp. -, 2026 (pdf). DOI:
- B. Siciliano,
L. Villani, G. Oriolo, A. De Luca, Foundations of Robotics,
Advanced Textbooks in Control and Signal Processing,
Springer Cham, 2025. DOI:10.1007/978-3-031-85523-8
- D. Marussi, M.
Cipriano , N. Scianca, L. Lanari, G. Oriolo, "Humanoid motion
generation in complex 3D environments," Robotics,
2025, vol. 14, no. 82, 2025 (pdf).
DOI:10.3390/robotics14060082
- S. Akbari , N.
Akbari , G. Oriolo , S. Galeani, "Visual urban navigation for
mobile robots: Implementation in the Duckietown environment,"
IEEE/IFAC 9th International Conference on Control Automation and
Diagnosis (ICCAD'25), July 1-3, 2025, Barcelona, Spain, 2025 (pdf). DOI:
10.1109/ICCAD64771.2025.11099311
- M.
Cipriano, G. Oriolo, A. Cherubini, "Singularity-free
trajectory tracking for steerable wheeled mobile robots,"
IEEE Robotics and Automation Letters,
vol. 10, no. 6, pp. 6199-6206, 2025 (pdf)
(link). DOI:10.1109/LRA.2025.3564209
- T.
Belvedere , M. Cognetti, G. Oriolo, P.
Robuffo Giordano, "Sensitivity-aware Model Predictive
Control for robots with parametric uncertainty,"
IEEE Transactions on Robotics, vol.
41, pp. 3039-3058, 2025 (pdf)
(link).
DOI:10.1109/TRO.2025.3554415
- N.
Scianca, F. M. Smaldone, L. Lanari, G.
Oriolo, "A feasibility-driven MPC scheme for robust gait
generation in humanoids," Robotics
and Autonomous Systems, vol. 189, 104957, 2025 (pdf) (link).
DOI:10.1016/j.robot.2025.104957
- G. Gasbarrone,
N. Scianca, L. Lanari, G. Oriolo, "A decentralized
cooperative transportation scheme for humanoid robots,"
2024 IEEE-RAS International Conference on Humanoid Robots
(Humanoids 2024), France, Nancy, pp. 381-387, 2024 (pdf)
(link).
DOI:10.1109/Humanoids58906.2024.10769869
- F. D’Orazio, T.
Belvedere, S. Tarantos, G. Oriolo, "Maintaining balance of
mobile manipulators for safe pick-up tasks," 18th
International Conference on Control, Automation, Robotics and
Vision (ICARCV 2024), Dubai, UAE, pp. 1207-1212, 2024 (pdf)
(link).
DOI:
10.1109/ICARCV63323.2024.10821705
- T. Belvedere,
N. Scianca, L. Lanari, G. Oriolo, "Joint-level IS-MPC: a
whole-body MPC with centroidal feasibility for humanoid
locomotion", 2024 IEEE/RSJ International Conference on
Intelligent Robots and Systems (IROS 2024), Abu Dhabi, UAE, pp.
11240-11247, 2024 (pdf)
(link).
DOI:10.1109/IROS58592.2024.10801628
- P. Carboni, G.
Nardini, E. Santini, G. Gravina, M. Cipriano, F. D'Orazio, T.
Belvedere, G. Oriolo, "A vision-based control scheme for safe
navigation in a crowd," 17th International Workshop on
Human-Friendly Robotics (HFR 2024), Lugano, Switzerland, pp.
73-83, 2024 (pdf)
(link).
DOI:10.1007/978-3-031-81688-8_6
- S. G. Tarantos,
T. Belvedere, G. Oriolo, "Dynamics-aware navigation among
moving obstacles with application to ground and flying robots,"
Robotics and Autonomous Systems, vol. 172, 104582, 2024
(pdf)
(link).
DOI:10.1016/j.robot.2023.104582
- M. Cipriano, M.
R. O. A. Maximo, N. Scianca, L. Lanari, G. Oriolo, "Feasibility-aware
plan adaptation in humanoid gait generation," 2023
IEEE-RAS International Conference on Humanoid Robots, Austin,
USA, pp. 1-8, 2023 (pdf) (link).
DOI:10.1109/Humanoids57100.2023.10375146
- M.
Cipriano, P. Ferrari, N.
Scianca, L. Lanari, G. Oriolo, "Humanoid
motion generation in a world of stairs," Robotics
and Autonomous Systems, vol. 168, 104495, 2023 (pdf) (link).
DOI:10.1016/j.robot.2023.104495
- M. Selvaggio,
A. Garg, F. Ruggiero, G. Oriolo, B. Siciliano, "Non-prehensile
object transportation via model predictive non-sliding
manipulation control," IEEE Transactions on Control
Systems Technology, vol. 31, no. 5, pp. 2231-2244, 2023 (pdf) (link).
DOI:10.1109/TCST.2023.3277224
- P. Ferrari, L.
Rossini, F. Ruscelli, A. Laurenzi, G. Oriolo, N. G. Tsagarakis,
E. Mingo Hoffman, "Multi-contact planning and control for
humanoid robots: Design and validation of a complete framework,"
Robotics and Autonomous Systems, vol. 166, 104448, 2023 (pdf)
(link).
DOI:10.1016/j.robot.2023.104448
Teaching
Old courses
- Applicazioni dell'Automatica: Introduction
to Mobile Robotics (up to 2024, 1 credito, Laurea in
Ingegneria Informatica e Automatica)
- Underactuated Robots (up to 2022,
3 credits, Master in Artificial Intelligence and Robotics,
Master in Control Engineering)
- Fondamenti di Automatica (up to 2018, 9
credits, Laurea in Ingegneria Elettronica; 6 credits, Laurea
in Ingegneria delle Comunicazioni)
- Elective in Robotics (up to 2011, Master
in Artificial Intelligence and Robotics; also Laurea
Magistrale in Ingegneria dei Sistemi, Laurea Magistrale
in Ingegneria Elettronica)
- 2010 SIDRA
Doctoral School on Robotics
- Controlli Automatici (Ingegneria Elettronica, vecchio
ordinamento)
- Controlli Automatici I modulo
(Laurea in Ingegneria Elettronica, ordinamento 509)
- Controlli Automatici II modulo
(Laurea/Laurea Specialistica in Ingegneria Elettronica,
ordinamento 509)
- Multi-Robot Systems (3 credits, Master in
Artificial Intelligence and Robotics, Master in Control
Engineering)
- Control of Autonomous Multi-Agent Systems
(6 credits, Master in Control Engineering)
- Sistemi Adattativi (Laurea
Specialistica in Ingegneria dei Sistemi e Laurea Specialistica
in Ingegneria Elettronica, ordinamento 509)
- Control of Nonholonomic Systems
(Corso di Dottorato in Ingegneria dei Sistemi)
- Complementi di Controlli
Automatici (Università di Roma Tre)
DIAG
Robotics Lab Homepage